Yacht Devices News: Autopilot: more control options, broader compatibility
Nov 20, 2026
We are releasing firmware version 1.06 for the Yacht Devices Autopilot YDAP-04. The update adds Simrad NSX support, direct rudder control from compatible joysticks and electronic steering wheels, a new Follow-Up mode, and a completely redesigned route-following algorithm. The new version incorporates the results of sea trials and feedback from users and installers.
The YDAP-04 combines a course computer and actuator control unit in a single housing. The standard NMEA 2000 network allows you to choose sensors, displays and controls from different manufacturers.
One of the main additions is direct rudder angle control. An external device sends the required rudder angle to the YDAP-04, and the autopilot operates the drive to move the rudder into position. This enables the use of compatible joysticks, electronic steering wheels and custom control panels that send commands over NMEA 2000.
We have added support for standard NMEA 2000 Group Function commands for PGN 127237 "Heading/Track Control". This interface also allows external devices to switch modes and set a target heading or wind angle, expanding integration options for navigation applications and onboard systems.
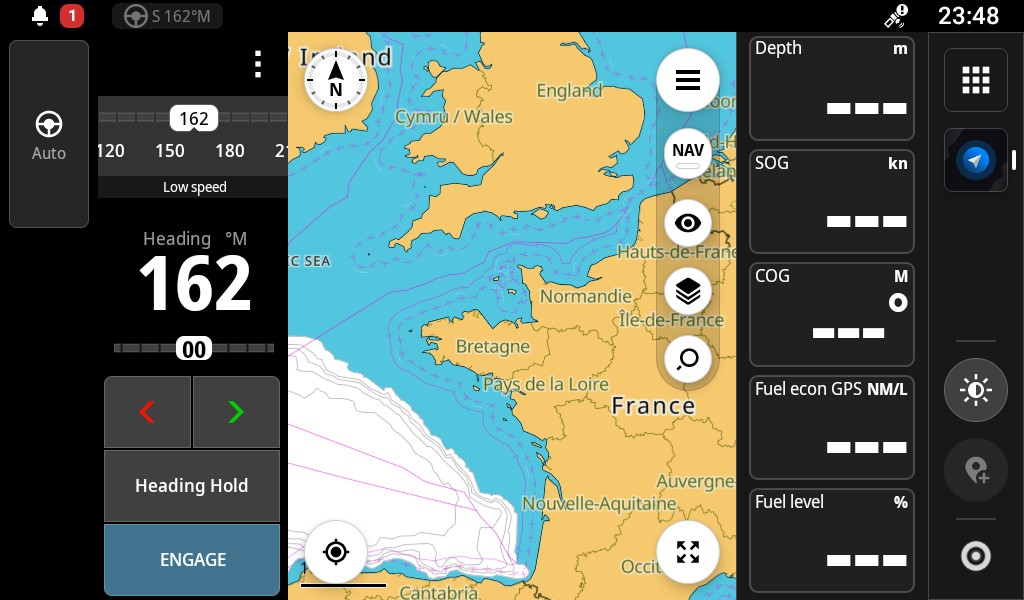
We have also completed integration with the Orca navigation system. Through Orca Core, YDAP-04 owners can switch modes, adjust heading and follow a route directly from a smartphone, tablet or Orca Display. Passage planning and autopilot control are brought together in one application. For sailing boats equipped with a wind sensor, Orca also supports wind angle steering and automatic tacking and gybing on command from the app. Before the manoeuvre, Orca displays its parameters and asks the helmsperson to confirm.
The new Follow-Up mode lets you command, for example, ten degrees of starboard rudder: the autopilot moves the rudder to that angle and holds it until the next command. The helmsperson steers the boat by adjusting the commanded rudder angle. This mode is available in the interfaces of compatible Simrad and B&G chartplotters. On the YDAP-04, it is called MANUAL and can also be operated from the button control panel.
For Simrad NSX owners, another addition is YDAP-04 control from the chartplotter’s built-in autopilot panel. To support this generation of displays, the YDAP-04 now identifies itself on the network as a Simrad NAC-3 rather than the older AC12. This allows you to use the familiar NSX interface with our autopilot.
We have completely redesigned the TRACK algorithm, which controls navigation along a route. When TRACK mode is engaged while the boat is off the route, it now joins the route along a smooth curve with an adjustable approach angle. Additional navigation data checks account for differences in how devices transmit their data, including the use of true and magnetic references.
Route completion handling has also been improved. Normally, the chartplotter should notify the autopilot when navigation has ended. The YDAP-04 can now also detect arrival using a configurable radius around the final waypoint. This allows it to switch from TRACK to AUTO and hold the current course if the chartplotter does not report the end of the route.
Support for steering systems has been expanded with a new mode for relay- and solenoid-operated systems. During automatic calibration, the drive now has more time to move: the timeout has been increased from 7 to 30 seconds. Rudder stall detection also takes the actual rudder movement speed into account, helping to avoid false detections with slower drives.
Compatibility with rudder angle sensors has been expanded, including support for the Navico RF-25, and handling of unreliable speed-through-water readings at low speeds has been improved. The heading adjustment step used with the X10 button can now also be configured to suit your preferences.
Thank you to everyone who shares their experience with the YDAP-04. Your feedback helps us account for the variety of real-world installations and continue improving the device after purchase.
Firmware version 1.06 is available on our website. The update is installed over NMEA 2000 using our free CAN Log Viewer software and a Yacht Devices gateway. Before updating, save your settings, and recalibrate the autopilot afterwards. Reverting to firmware version 1.05 or earlier will reset the settings to factory defaults. Technical changelog (for installers & advanced users) is available here.